Technical Field
This invention relates to stepless speed regulating device, in particular, relates to a stepless speed-regulating device of the generator for the marine generator.
Background Art
On fishing vessels for ship generator is widely applied, its drive unit (for example, diesel engine) power generation at the same time also needs to perform other work, the need to change the rotational speed of the drive unit is adjustable, and the generator in the power generation is relatively constant for the rotational speed of the input, hence the need for a special power generation the companion unit to the driving unit of the generator, this results in the structure of the whole power system becomes complicated, but also increase power system the energy consumption and the cost of purchase.
Content of the invention
The purpose of this invention is to provide a stepless speed-regulating device of the generator for ship and ship generator, in order to solve for ship in the prior art large variation in rotation speed of the drive unit, cannot be used for power generation, require the use of special of the technical problem of generating an auxiliary machine.
To achieve the above object, according to one aspect of the invention, provides a marine generator stepless speed-regulating device, stepless speed-adjusting device includes: a driving belt pulley assembly, the metal strap, passive belt wheel assembly, fixed-shaft gear train speed reducing device and the planetary mechanism, driving belt wheel assembly through the metal strip is connected with the driven belt wheel assembly; a fixed shaft gear train of the speed reducing device is connected with the 1st gear 2nd gear pair; 1st gear pair is connected with the driven belt pulley assembly, 2nd gear pair is connected with the planetary mechanism; the planetary mechanism includes a driving belt pulley assembly is connected with the sun gear, and the sun wheel engaging the star wheel, the star wheel engagement exercise exercise of star wheel, and the outer planetary the wheel gnaws ring gear and the output power of the combined used for supporting the exercise of the star-wheel and star wheel of the planet carrier, the planet carrier is connected with the 2nd gear pair.
Furthermore, the 1st gear 2nd gear pair are provided with the drive gear and the driven gear; 1st the drive gear of the gear pair and the driven belt pulley assembly, a driven gear of the gear pair are 1st and 2nd the drive gear of the gear pair is fixed on the same shaft, 2nd driven gear of the gear pair and is connected with the planet carrier of the planetary mechanism.
Furthermore, passive belt wheel assembly includes as a symmetry axis symmetrically arranged to the passive belt wheel and a driven belt wheel shaft; and the driven belt wheel 1st is connected with the drive gear of the gear pair.
Furthermore, passive belt wheel is the conical disc-shaped, may slide on the driven belt wheel.
Furthermore, a driving belt wheel assembly comprises a to the axis of symmetry of the symmetrically arranged driving belt wheel shaft and the driving pulley; and the driving belt wheel is connected with the sun wheel of the planetary mechanism.
Furthermore, driving belt wheel is the conical disc-shaped, may slide on the driving belt wheel.
According to another aspect of the invention provides a marine generator, which comprises a driving unit, stepless speed regulating device and a generator, for the above stepless speed regulating device for marine generator stepless speed-regulating device; driving unit is connected for ship stepless speed control device of the generator driving belt wheel assembly, for ship generator of the generator and stepless speed control device is connected with the gear ring of the planetary mechanism.
Furthermore, the driving unit is a diesel engine.
The invention has the following beneficial effects:
dead axle gear train planetary mechanism and the speed reducing device and the metal belt type stepless speed change device, speed ratio of the system range is adjustable, so that the metal belt type stepless speed change device with the required speed ratio range of the speed ratio range matching, the driving unit and a variable speed input into a constant speed output, the drive unit can directly drive the generator to generate electricity the operation, simplify the structure of the power system, the energy consumption and the cost is reduced.
In addition to the above the purpose of the description, features and advantages, the invention also has other objectives, features and advantages. Will be with reference to Figure, this invention for further detailed description.
Description of drawings
Form a part of this application the Figure this is used to provide further understanding of the invention, illustrative embodiments of the invention the note for the interpretation of this invention, does not constitute the limits of this invention. On the drawings:
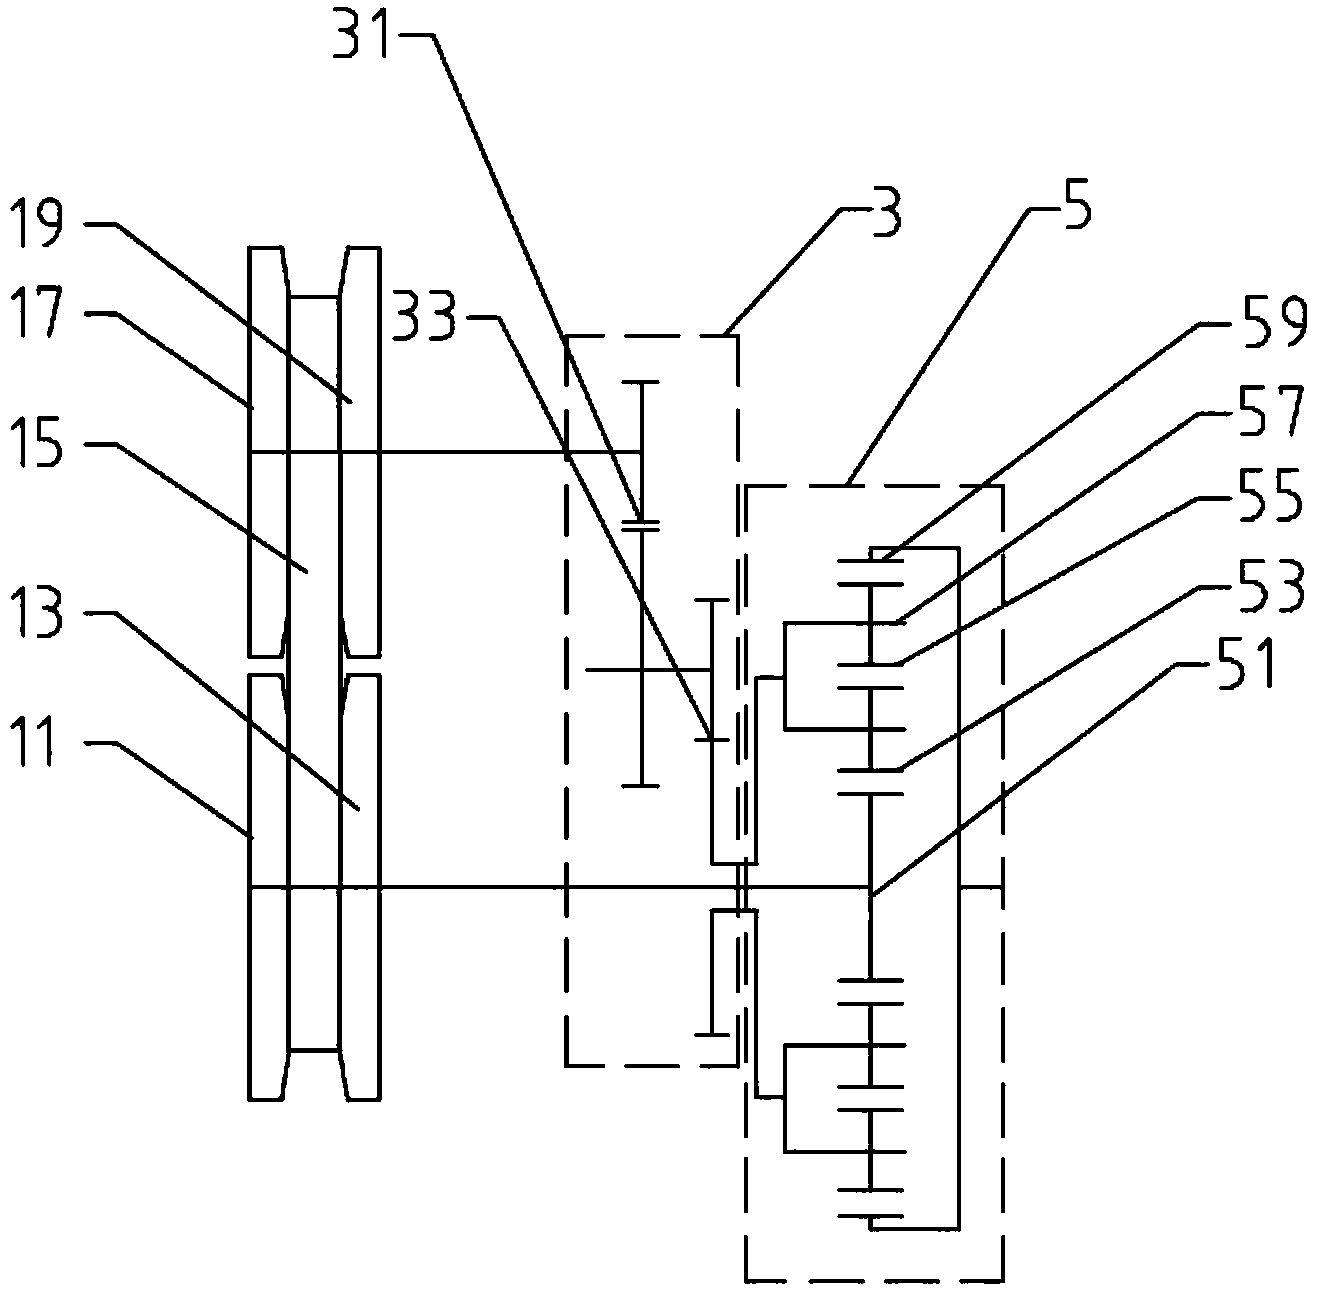
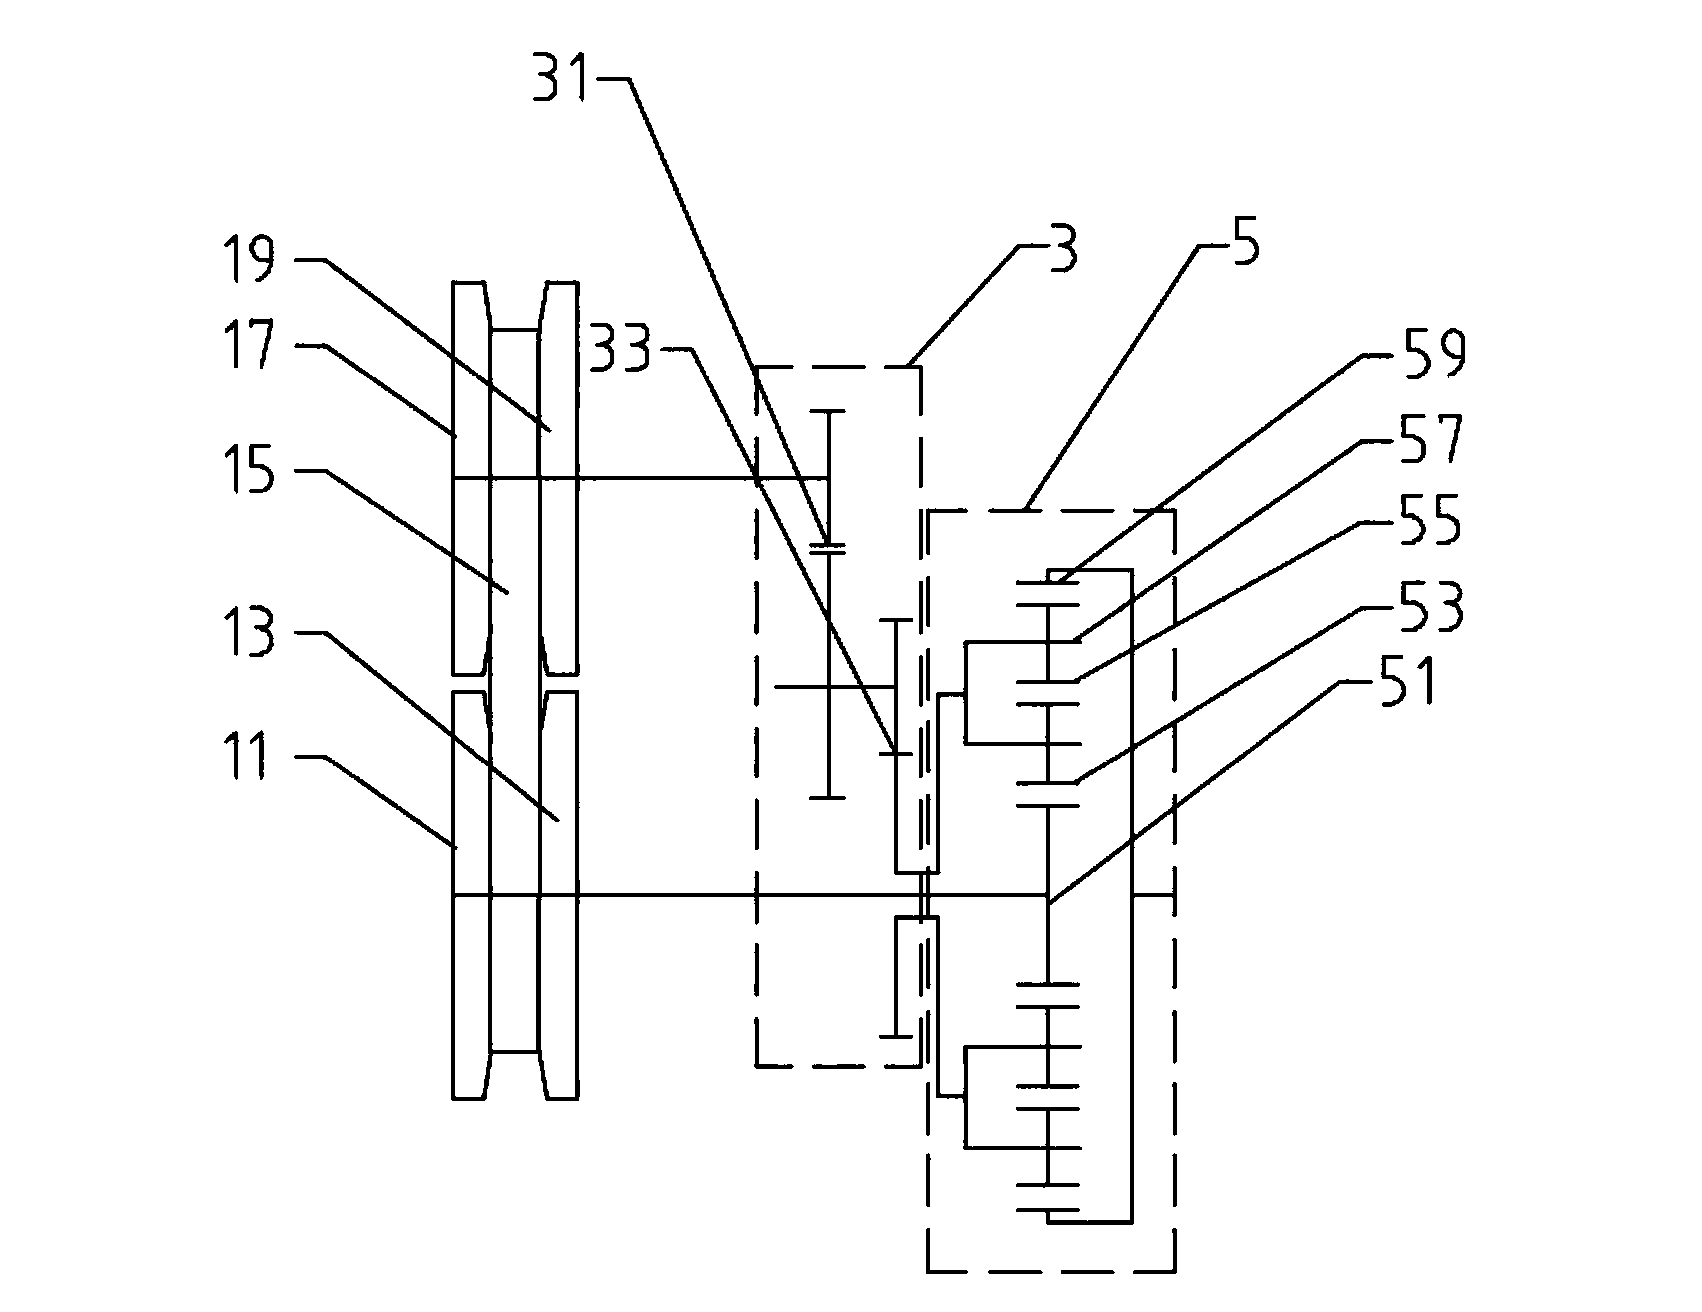
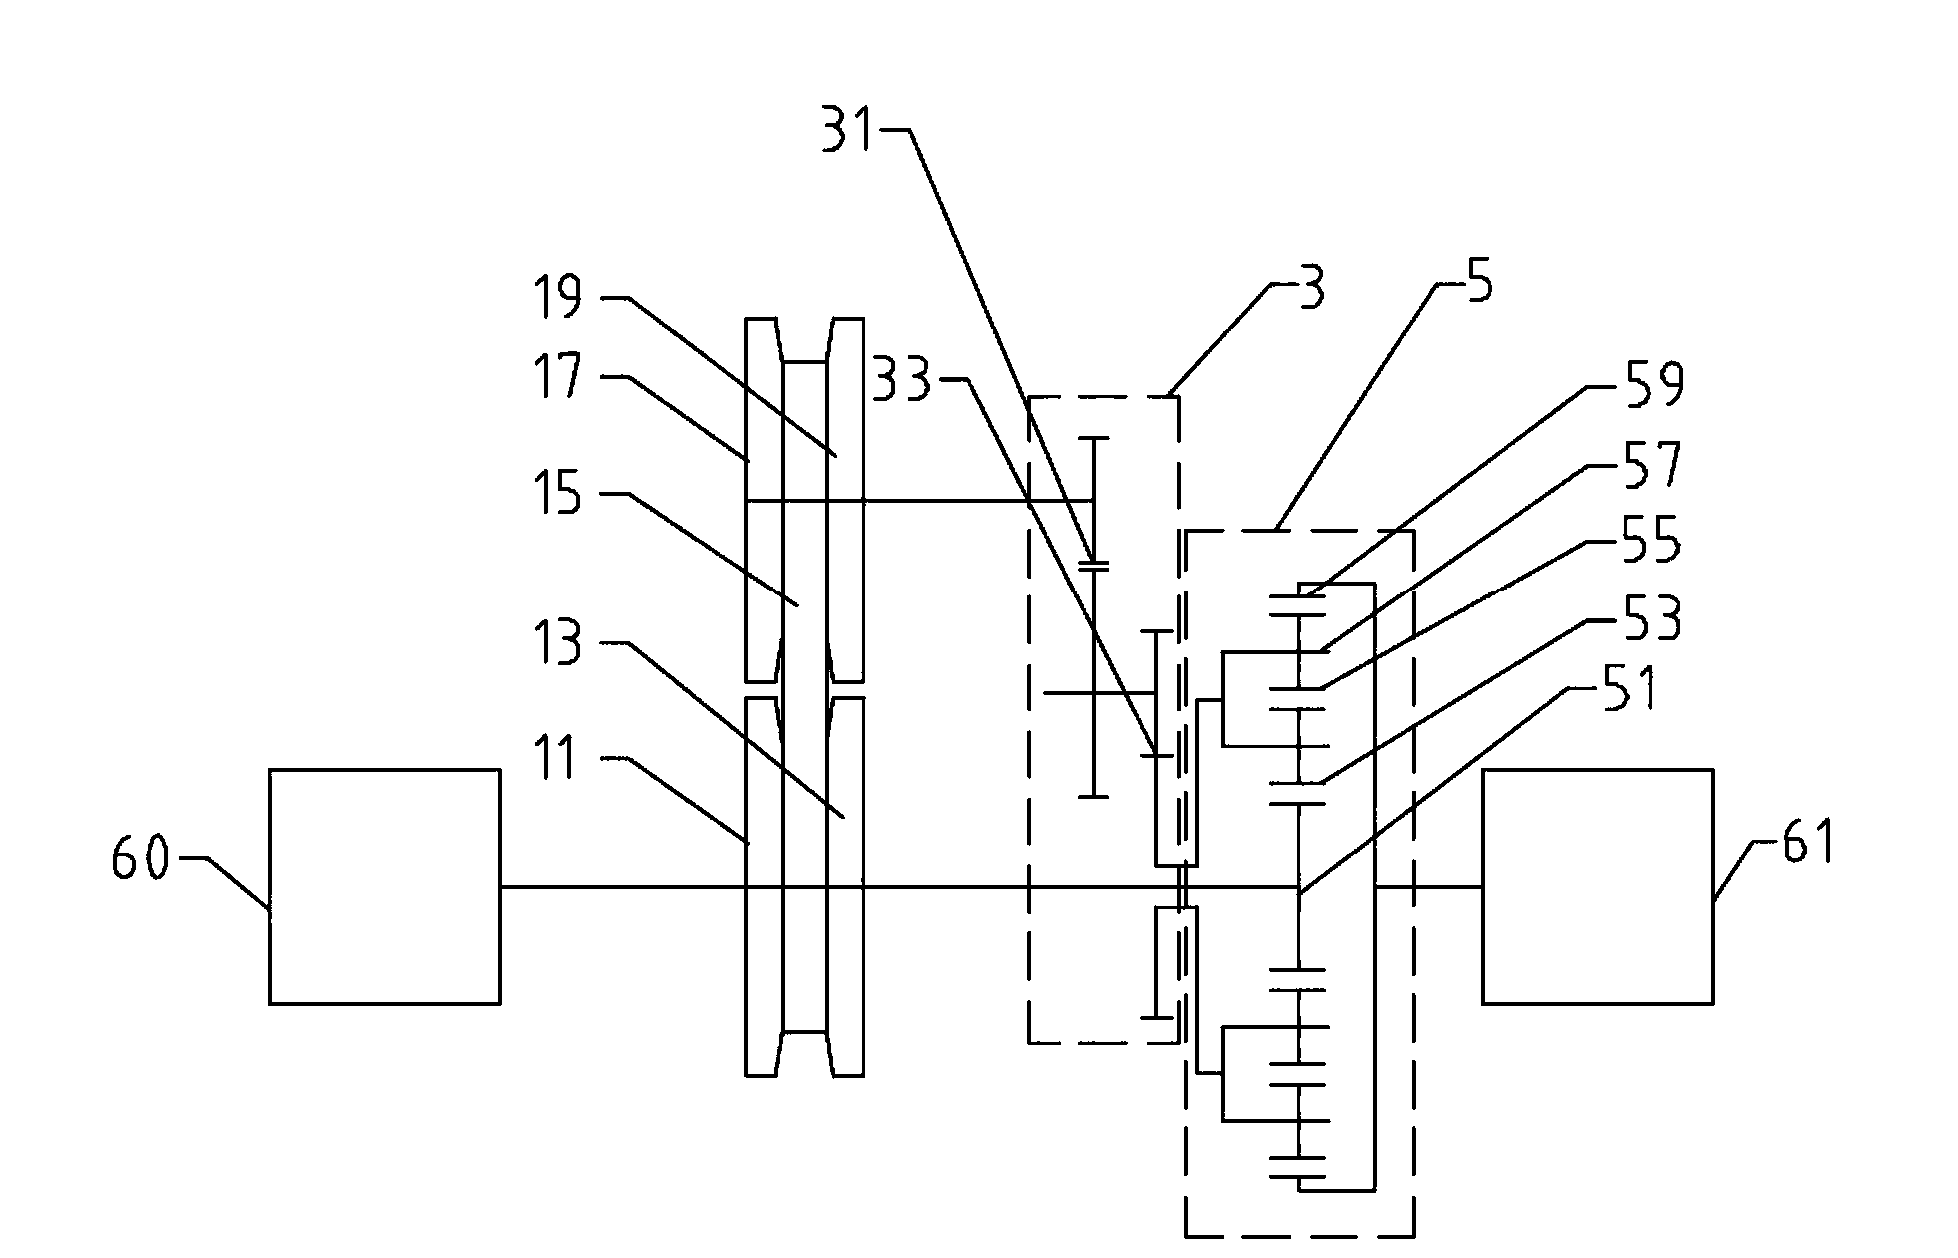
Figure 1 is a structure diagram of the invention marine generator stepless speed-regulating device the preferred embodiment; and
Figure 2 is a structure diagram of the invention marine generator preferred embodiment.
The Figure mark note:
11, driving belt wheel; 13, driving pulley; 15, metal strip; 17, passive belt wheel; 19, passive belt wheel shaft; 3, deceleration device dead axle gear train ; 31, 1st gear pair; 33, 2nd gear pair; 5, the planetary mechanism; 51, sun gear; 53, mavens star wheel; 55, laity star wheel; 57, planet carrier; 59, ring gear; 60, drive unit; 61, generator.
Mode of execution
The following illustrated in the Figure the embodiment of the present invention to carry out a detailed description, however, the invention is defined by claims and covers the implementation of a plurality of different ways.
Please refer to fig. 1, the preferred embodiment of the present invention provides a marine generator stepless speed-regulating device, including: a driving belt pulley assembly, metal belt 15 and the driven belt pulley assembly, a driving belt wheel assembly through the metal belt 15 and the driven pulley assembly is connected; and, fixed-shaft gear train speed reducing device 3 and the planetary mechanism 5. dead axle gear train reduction device 3 comprises connected 1st gear pair 31 and the 2nd gear pair 33 ; 1st gear pair 31 is connected with the driven belt pulley assembly, 2nd gear pair 33 and the planetary mechanism 5 is connected. Planetary mechanism 5 is a double-planet wheel of the planetary mechanism, comprising a driving pulley connected with the assembly of the sun gear 51, the sun gear 51 engaging the star wheel 53, and expert star wheel 53 is meshed with the laity star wheel 55, and the outer planetary gear 55 is engaged and the gear ring of the output power of the 59 and is used for supporting the planet wheel 53 and star wheel 55 a planet carrier 57, the planet carrier 57 is connected with the 2nd gear pair 33.
The preferred embodiments provide for ship of stepless speed-regulating device of the generator, the implementation process is as follows:
Power from the driving pulley assembly input, then output through two paths: one path of the metal strip 15 is transmitted to the driven belt wheel assembly, then after deciding shaft gear train reduction device 3 of the 1st gear pair 31 and the 2nd gear pair 33 is transmitted to the planetary mechanism 5 a planet carrier 57 ; the other path is from the driving belt wheel assembly directly input to the planetary mechanism 5 the sun gear 51, the planetary mechanism 5 from the planetary mechanism after synthesis 5 of the ring gear 59 output. Such a driving belt pulley assembly, metal belt 15 and the driven pulley assembly stepless speed adjusting device realizes stepless speed-regulating, dead axle gear train speed-reducing device 3 and the planetary mechanism 5 the function of adjusting the metal strip 15 the effect of torque transmitted by a; the stepless speed-changing mechanism of the variable speed ratio range is relatively fixed, fixed-shaft gear train speed reducing device 3 and the planetary mechanism 5 the role of the function of adjusting the speed-ratio range.
In order to simplify the dead axle gear train speed-reducing device 3, driving pulley assembly and a driven belt wheel assembly structure; preferably, 1st gear pair 31 and the 2nd gear pair 33 are provided with the drive gear and the driven gear; 1st gear pair 31 of the drive gear and the driven belt pulley assembly, 1st gear pair 31 of the driven gear and 2nd gear pair 33 of a drive gear fixed on the same shaft, 2nd gear pair 33 and the driven gear of the planetary mechanism of 5 the planet carrier 57 is connected. Passive belt wheel assembly including a metal strip 15 arranged symmetrically to the symmetry axis of the driven pulley 17 and the driven belt wheel shaft 19, driving belt wheel assembly including a metal strip 15 arranged symmetrically to the symmetry axis of the drive belt wheel shaft 11 and driving pulley 13 ; driving belt wheel 11 and the driven belt wheel 17 is located in the metal strap 15 on one side of the, driving pulley 13 and the driven belt wheel shaft 19 is located in the metal strap 15 a side of the other. Passive belt wheel 19 and the 1st gear pair 31 is connected with the driving gear, the driving belt wheel shaft 11 and the planetary mechanism 5 the sun gear 51 is connected with.
Preferably, passive belt wheel 17 has a tapered disc-shaped, will be passive belt wheel 19 sliding on the; driving belt wheel 13 has a tapered disc-shaped, will be driving belt wheel 11 sliding on. This kind of structure, the driving belt wheel assembly can be adjusted, the driven belt wheel assembly of the metal strip 15 of the contact radius, in order to better achieve the purpose of stepless speed regulation.
Please refer to fig. 2, the preferred embodiment of the invention also provides a use of the above-mentioned ship stepless speed control device of the generator for marine generator, comprising the driving unit 60, stepless speed regulating device and a generator 61 ; the drive unit 60 is connected with the generator for the driving belt stepless speed control device driving belt wheel of the wheel assembly 11, the generator 61 of the generator and ship planetary mechanism of a stepless speed control device 5 of the ring gear 59 is connected. Preferably, the drive unit 60 to a diesel engine.
The preferred embodiment provides a marine generator, its specific realizing process is as follows:
Drive unit 60 output speed n 0 the stepless speed regulating device (speed ratio i c) and dead axle gear train reduction device 3 (speed ratio i g) after the speed change, the planet carrier 57 the rotating speed of the n c = n 0/i c i g. At the same time, because the sun gear 51 and the driving belt wheel shaft 11 is connected, its rotational speed and drive unit 60 is the same as the rotational speed of, in other words n 0, according to the characteristics of the planetary mechanism, a double-planet wheel of the planetary mechanism, a:
n s-an r + (a-1) n c = 0, wherein a is a planetary mechanism of the characteristic parameter, its value is the ring gear and sun gear of the gear ratio.
Therefore:
From the drive unit 60 to the input of the ring gear 59 of the speed ratio output of:
Wherein i g is a fixed value, i c the i cmin-i cmax continuous change in the, speed ratio range ![]() Therefore i can also be continuously changed within a certain range, its variation range:
That is, the speed ratio range is:
On a particular stepless speed change device, d c and i cmin as definite value, the ![]() Value, can get the required d o value, such as, d c = 5.5, i cmin = 0.4, need d o = 1.667, the
![]() Value 0.383.
Visible, fixed-shaft gear train speed reducing device 3 and the planetary mechanism 5 according to the role of the range needs to be adjusted.
The purpose of this invention lies in the change of the input speed rotary n 0 into the constant output speed n (n=n r), by the formula:
Failure, when the a, n r, i g when as the fixed value, n 0 and i c the relationship between the one-to-one corresponding to a, through the speed sensor reading input speed n 0, control the speed ratio of the stepless speed change device for i c constant can be obtained n the output rotational speed.
The device also can achieve stepless speed change of the input speed rotary n 0 to constant output rotational speed of the conversion of n, but the existence of the following questions:
1) a stepless speed control device with the required speed ratio range of the speed ratio range is not matching, using dead axle gear train speed-reducing device 3 and the planetary mechanism 5 solves this problem.
2) allow stepless speed regulating device for the maximum input torque, and the driving unit 60 the maximum output torque is not matching, there may be drive unit 60 the maximum output of the condition of excessive torque.
Stepless speed regulating device for use alone, passive belt wheel shaft 19 to the torque T sec = i c T 0 (T 0 the input torque). By adding fixed-axis gear train speed reducing device 3 and the planetary mechanism 5 the rear, according to the characteristics of the planetary mechanism, the sun wheel 51 of the torque for T s, planet carrier 57 torque T c = (a-1) T s, ring gear 59 torque T r =-aT s, and the whole transmission system has: T out = T r =-iT 0, therefore:
Passive belt wheel shaft 19 of the torque
Because i c i g> 0, therefore,
Visible, adding fixed-axis gear train speed reducing device 3 and the planetary mechanism 5 rear, reduced torque stepless speed control device, and, can be by parameter a, i g adjustment, the stepless speed-regulating device with the input of the value of the torque.
From the description above, as can be seen, the embodiment of the present invention to realize the above-mentioned technical effects as follows:
1, stepless speed-regulating device utilizes the metal belt type stepless speed change device as the speed-regulating device, have realized the drive unit 60 of the variable speed input into a constant speed output.
2, the use of a planetary mechanism 5 and dead axle gear train speed reduction device 3 is combined with the metal belt type stepless speed change device, speed ratio of the system range is adjustable, so that the metal belt type stepless speed change device with the required speed ratio range of the speed ratio range matching.
3, the use of a planetary mechanism 5 and dead axle gear train speed-reducing device 3, metal belt type stepless speed changing device can be reduced by the torque, so as to make its size is small, the structure is more compact; and planetary mechanism can be changed 5 and dead axle gear train speed-reducing device 3 to adjust the parameters of the metal belt type stepless speed changing device of the size of the torque, the same is a belt type stepless speed change device to meet different driving unit 60 needs, the product is easy to mass, serialization.
Above for the stated example the preferred embodiment of the invention, is not used for limiting of the present invention; to persons of skill in the art, the invention may be of various variation and change. Where in the present invention within the spirit and principle of the, any modifications made by the, equivalent replacement, improved, and the like, shall be included in the scope of protection of this invention.
Stepless speed regulation device of marine generator and marine generator




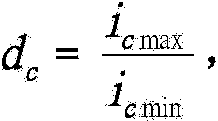
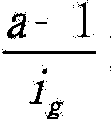



 400-4929-0909
 contact@catarc.com.cn

